Hi all,
Has anyone loaded a QuantStudio 5 with a robot arm (e.g. a PF400)?
My main concerns:
- room for the gripper to place the plate in the drawer
- the need for pressing down from the top of the plate to seat it
Thanks!
Hi all,
Has anyone loaded a QuantStudio 5 with a robot arm (e.g. a PF400)?
My main concerns:
Thanks!
thermo sell a full automation kit for this
My team has been loading it with an Thermo orbiter arm no problem.
awesome, thank you!
Yes we have done exactly this.
You have multiple options here:
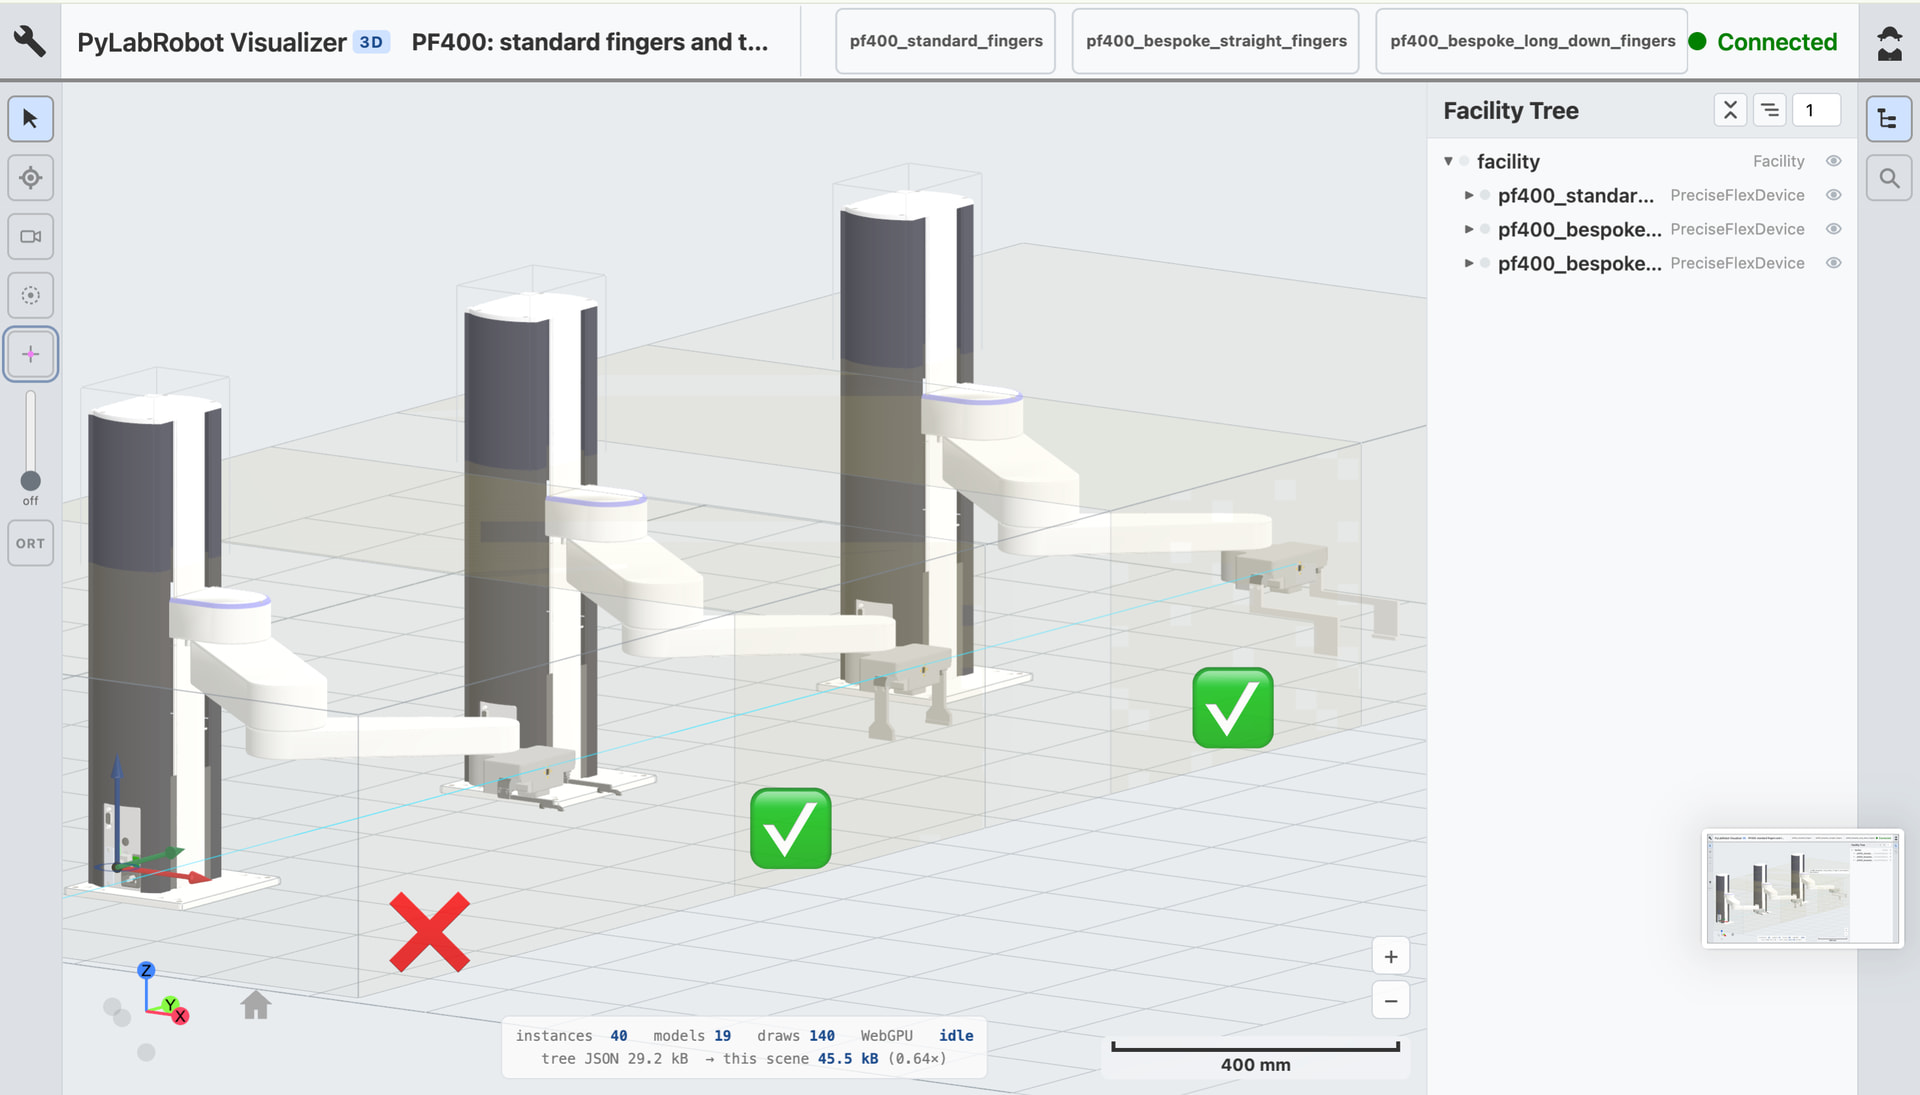
The original issue with the loading is the approach and access of the drawer system of the QuantStudio + embedded plate arrangement + the fact that the PF’s standard grippers are just straight.
You can design your own fingers which are just going either (1) straight down (see middle), or (2) forward and then straight down (see right).
The PF400’s server then simply needs an update you can add to it for the “tool” / gripper offset which it stores internally.
Hope this helps 
@CamilloMoschner thank you, really appreciate the explanation! It was very helpful. And the 3d PLR visualizations are