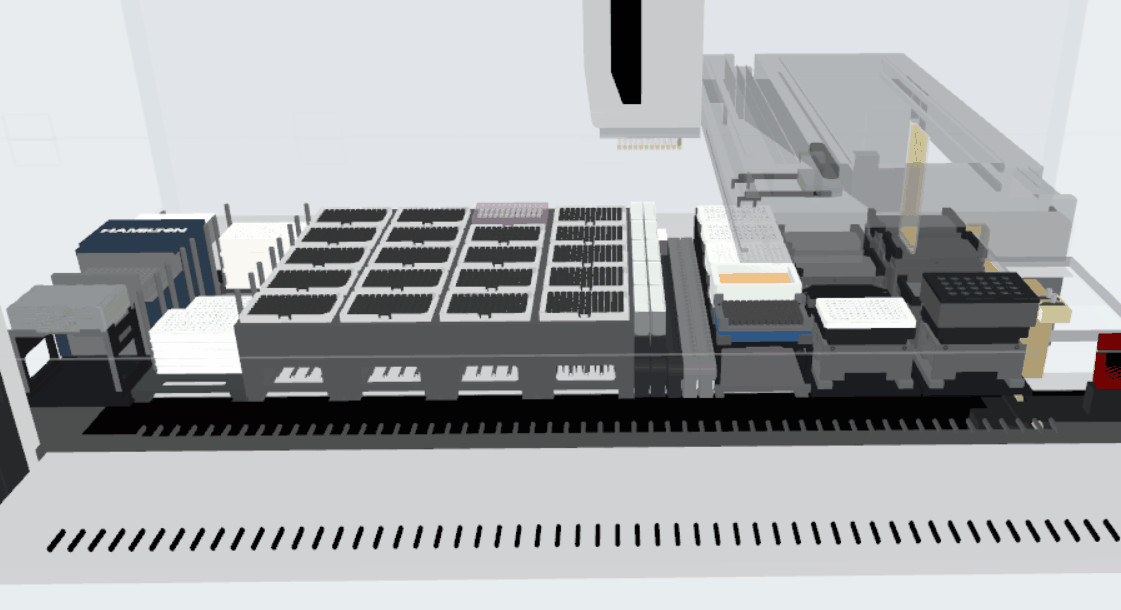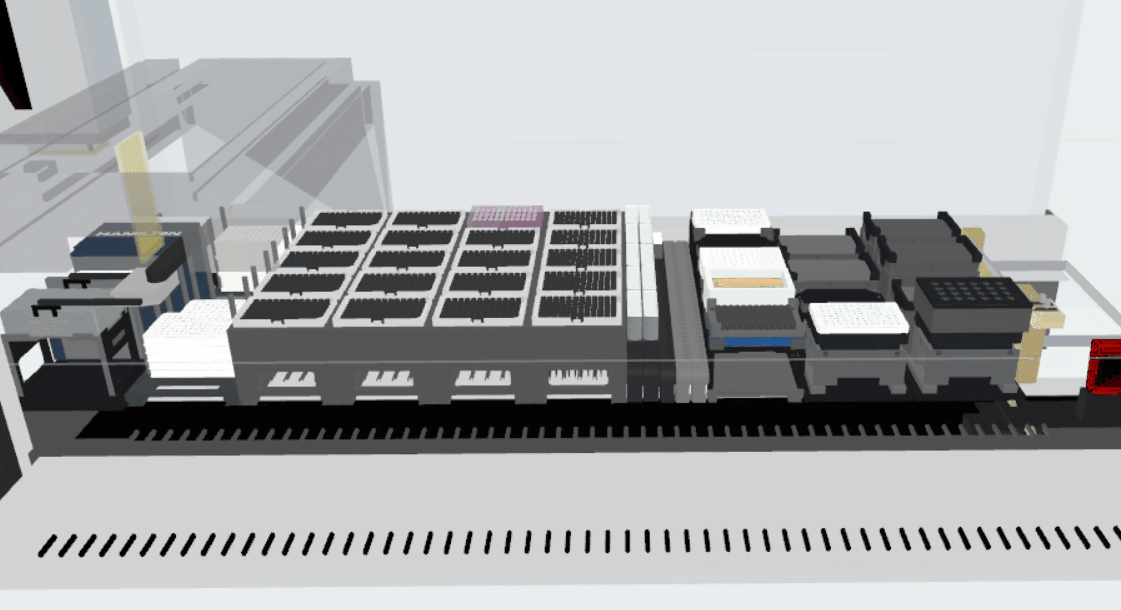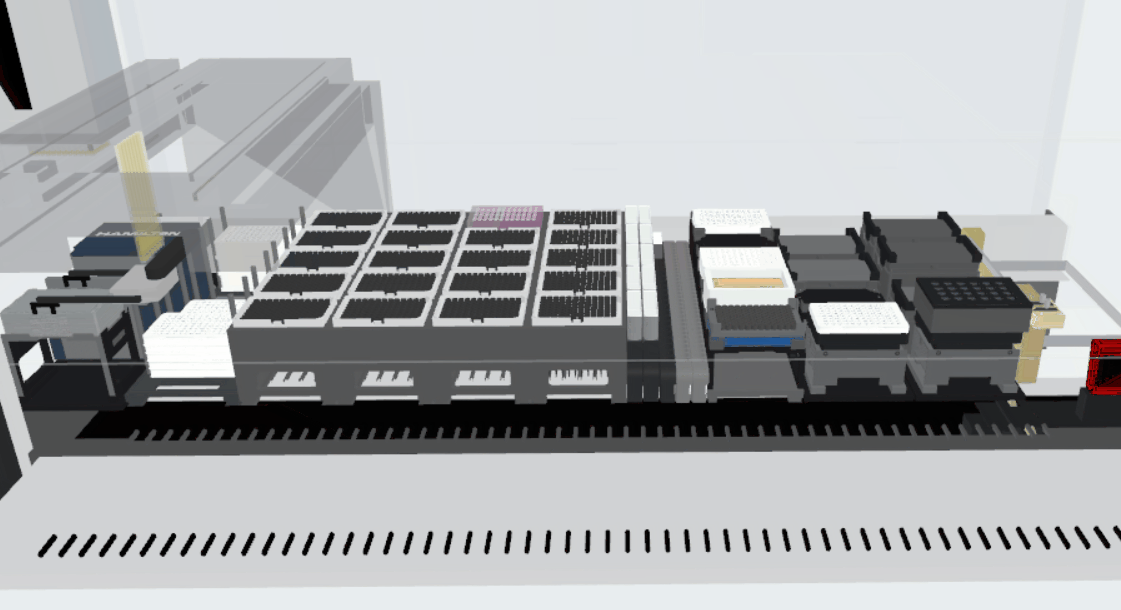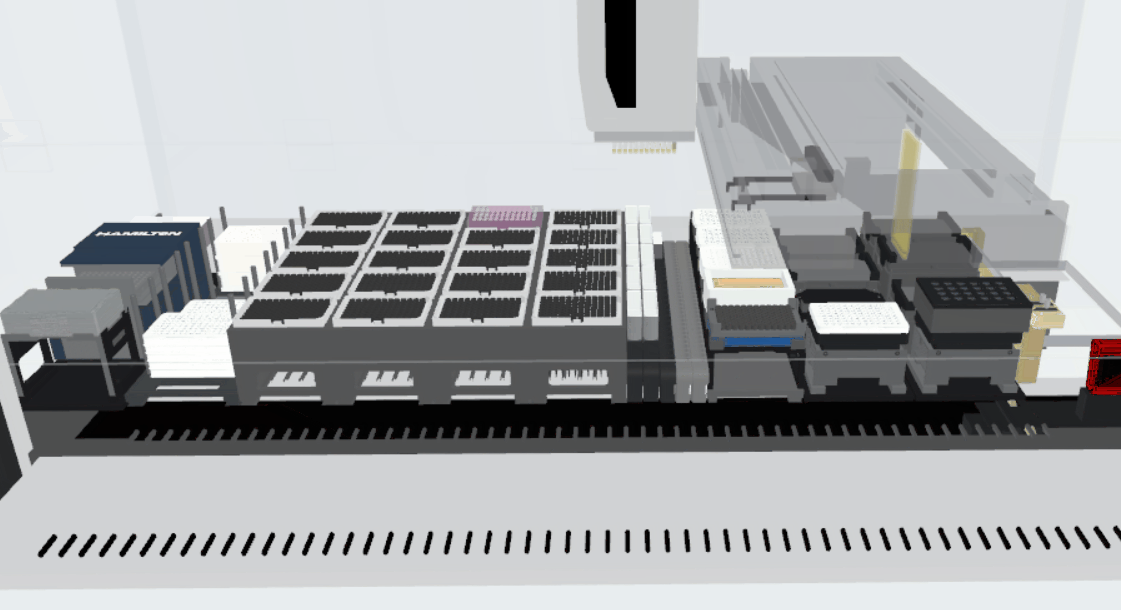
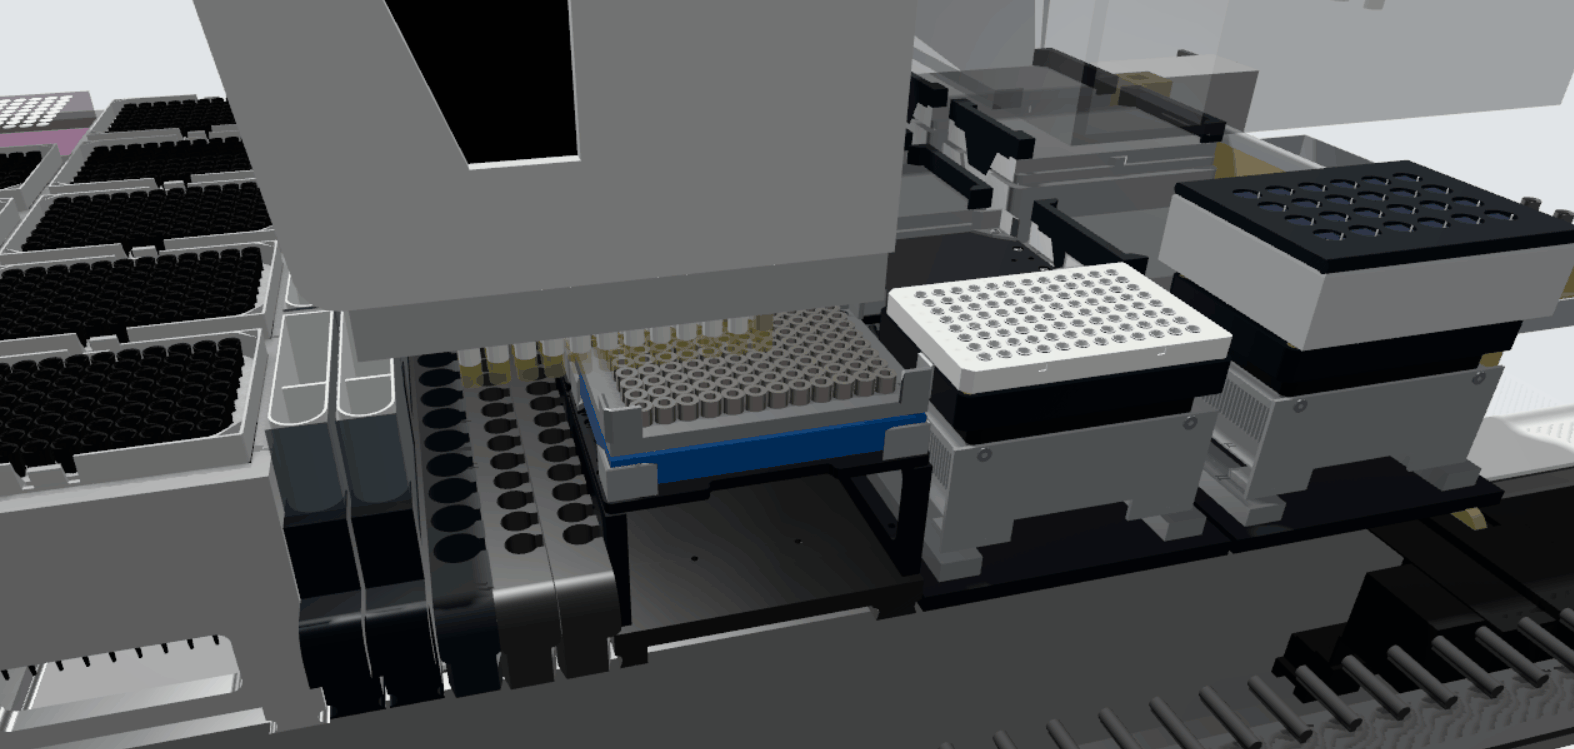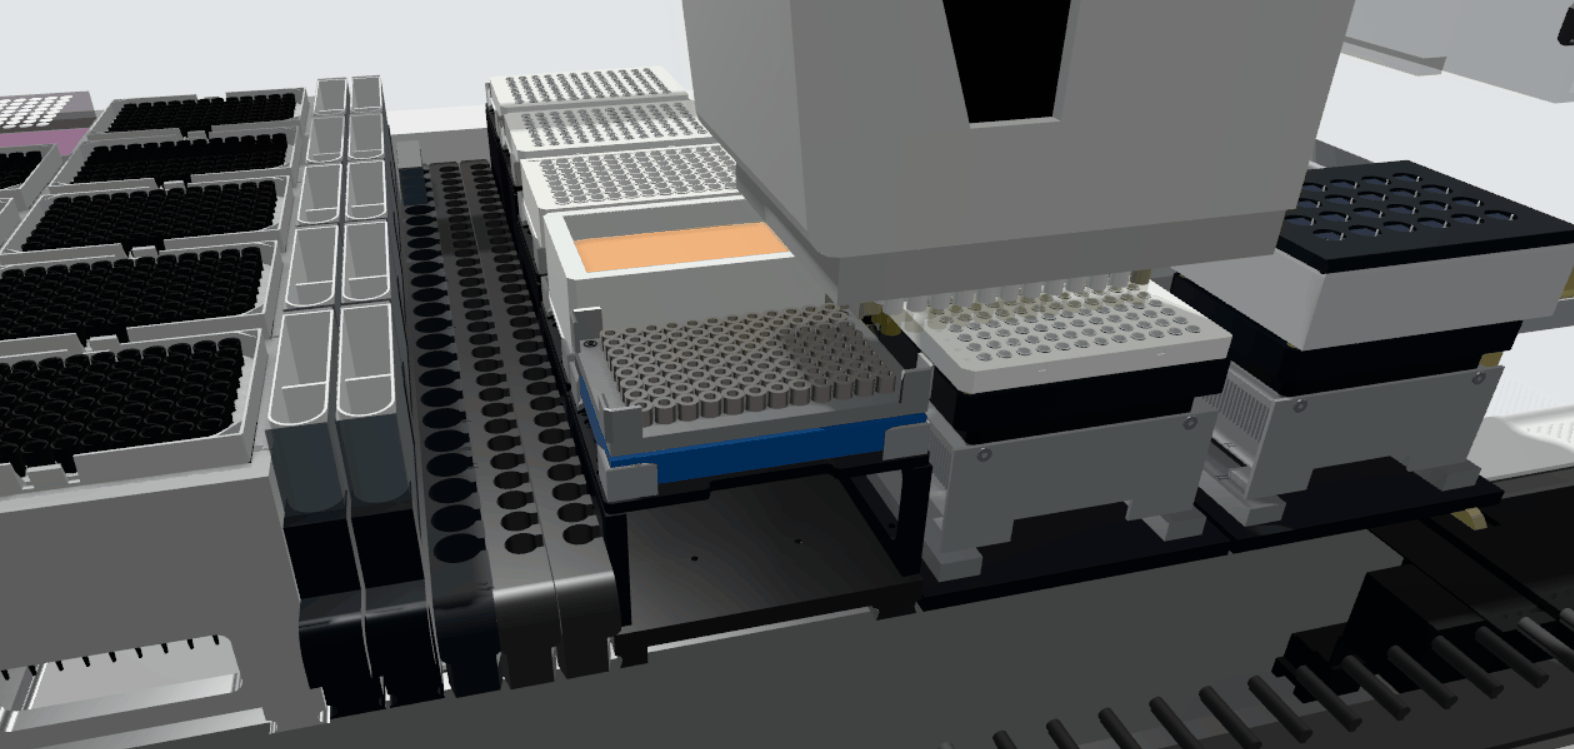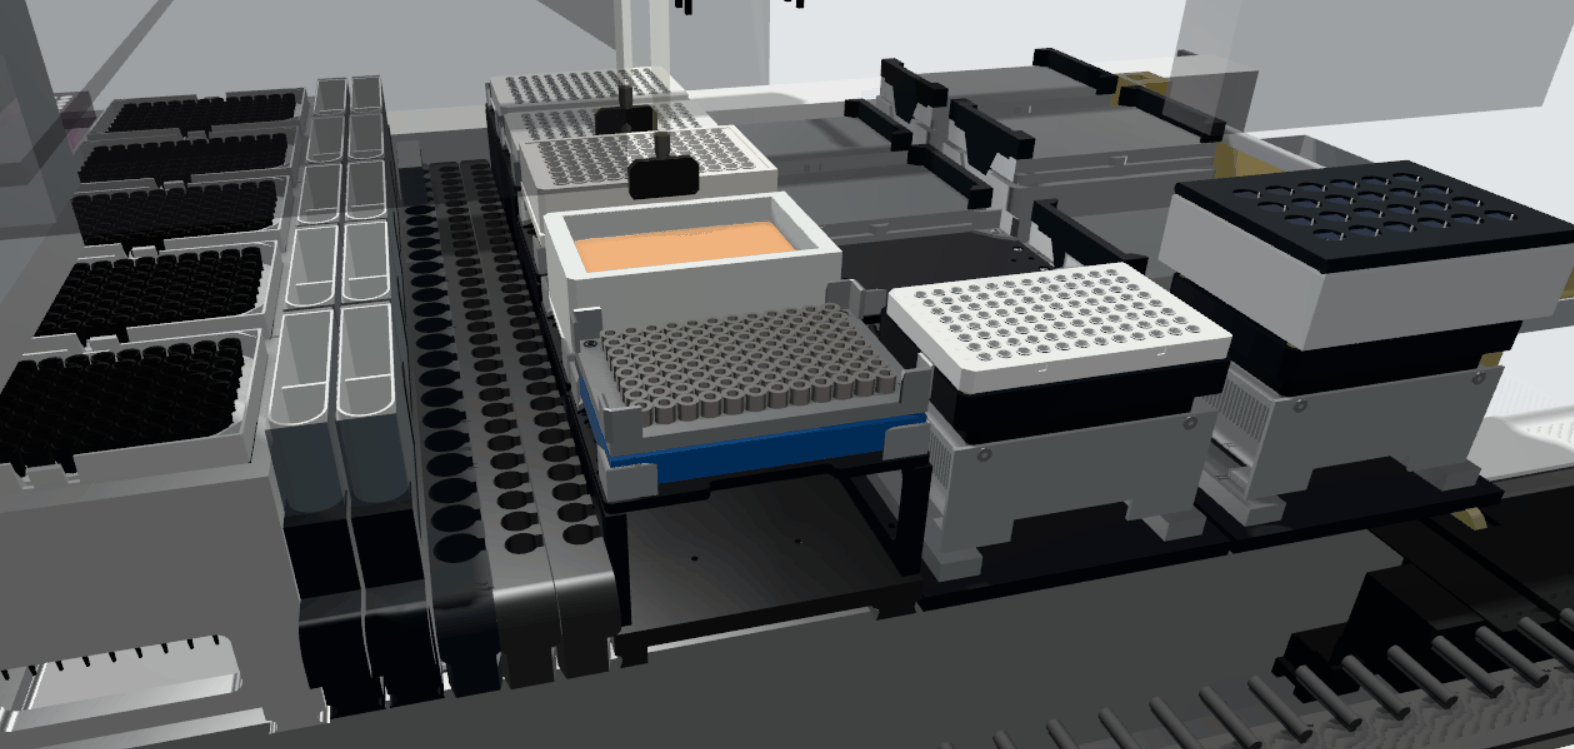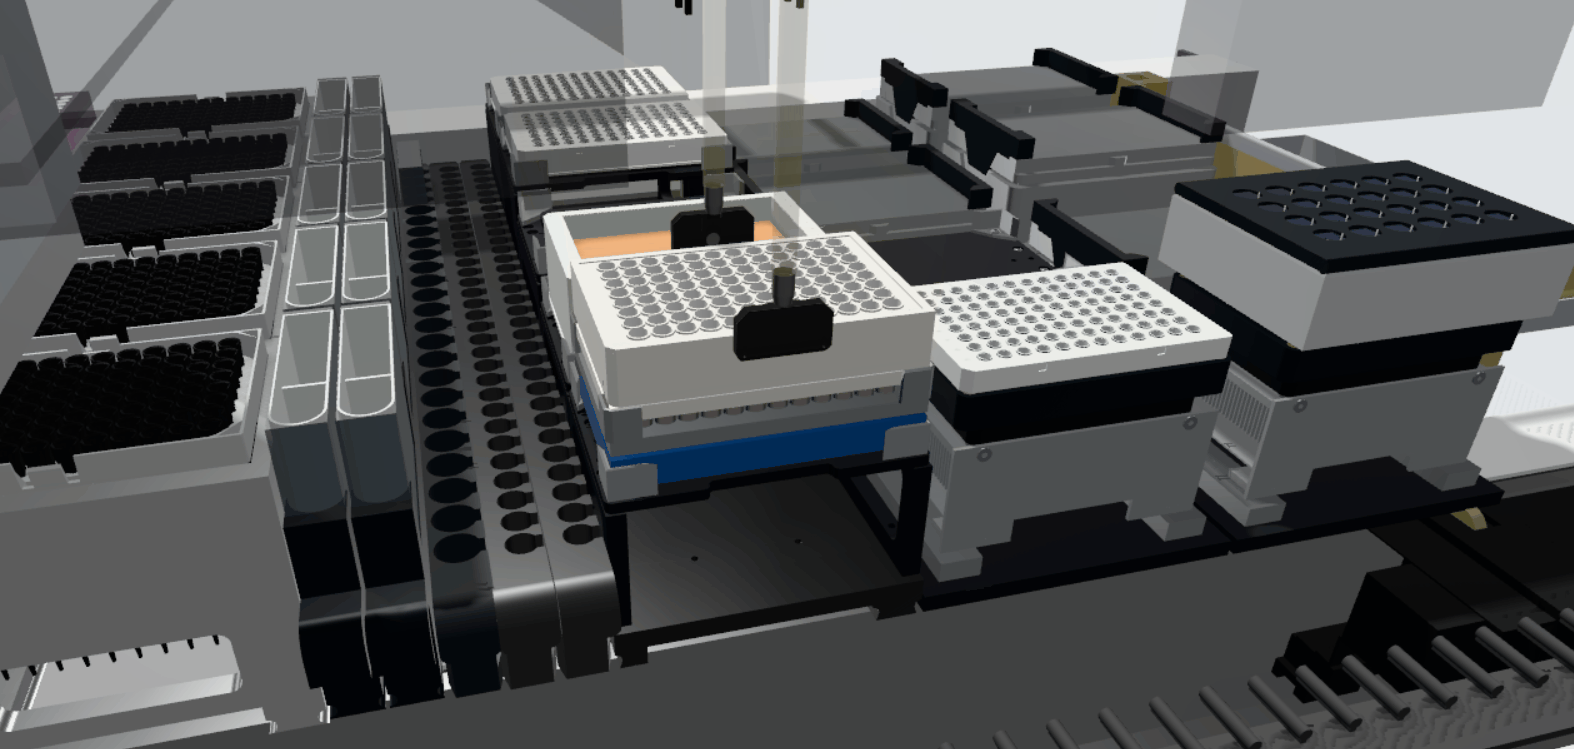
PLR now has a 3D visualizer, I think this is going to be a very powerful tool. We have never had the ability to see in full geometric detail a model of precise actions like iSWAP movements to off-deck instruments or exactly where the pipette tip goes in a plate. This simulation is driven by firmware commands, so it’s meant to be an exact representation of how the robot will respond.
The visualizer is public on the main PLR branch now, but it’s also heavily in development still. The demo below is produced from my own fork that I am also updating frequently.
Thank you, Stefan, for promoting the 3D PLR Visualizer which @rickwierenga and I built in a massive push of features for the first PLR workshop in Copenhagen this week.
We are excited for you to contribute some PRs soon to the project, your additional 3D models and advancements to the movement simulations would be fantastic additions.
I should mention though that the 3D Visualizer is currently a beta release, and we are still improving it and the required v1 integration architecture of devices before an official pypi release.
Shadows are not bad since i had it only recompute for static resources instead of having shadows cast by all the mobile elements
PBR definitely adds something but I got a lot back by removing (for these renders) transparent elements like enclosures which require shading the same pixel multiple times and also heavily downsampling certain models. Not sure what the exact change is though.